
#Industry News
Why Electric Robot Joint Actuators Are Replacing Hydraulic Systems in Humanoid Robots?
Electric robot joint actuators enable more efficient, compact, and precise humanoid robots.
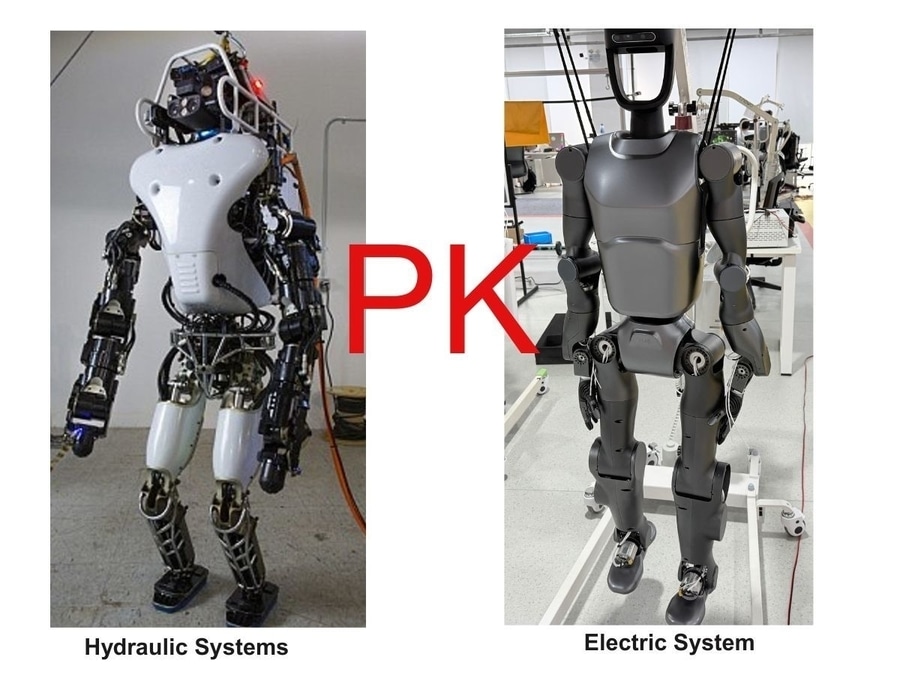
As humanoid robots move from research and development toward real-world applications, joint actuation systems face higher demands for efficiency, precision, compactness, low weight, reliability, and integration. Compared with hydraulic systems, electric robot joint actuators are well suited to battery-powered and distributed joint architectures, integrating components such as harmonic reducers, planetary gearboxes, encoders, drivers, and sensors into compact motion systems. This article compares electric and hydraulic actuation and explores the roles of harmonic reducers, planetary gearboxes, and planetary roller screws in different humanoid robot joints, while explaining how to select the appropriate actuator architecture based on torque, speed, precision, load, and space requirements.