
#Product Trends
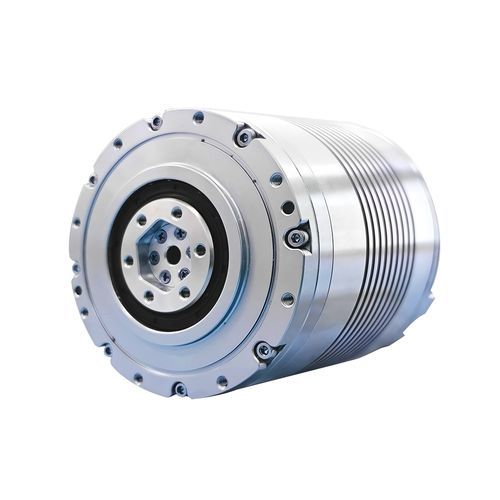
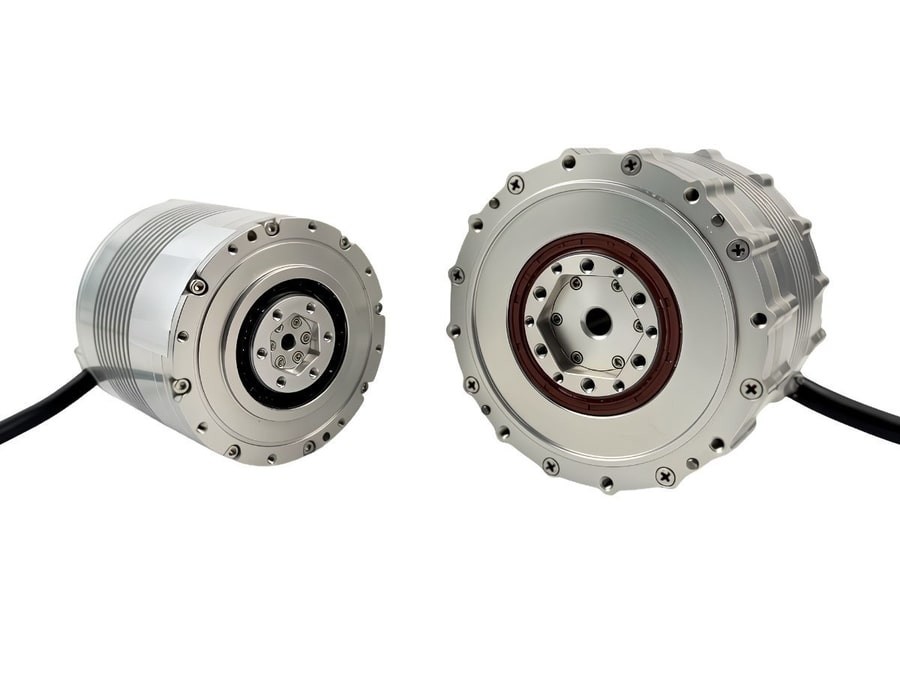
Quadruped Robot Joint Solutions with HONPINE JRM Planetary Joint Module
How Does the HONPINE JRM Planetary Joint Module Solve Key Performance Challenges in High-Dynamic Quadruped Robots?
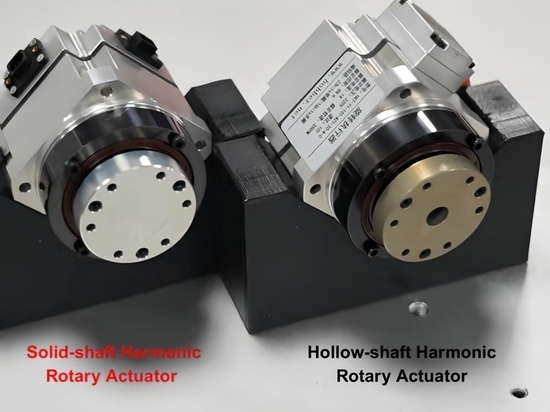
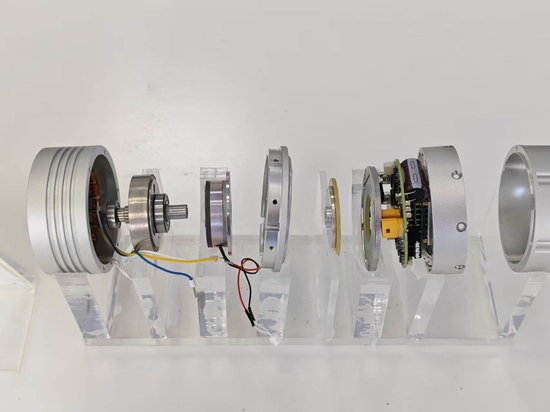
Quadruped robots operating in complex environments face demanding requirements for joint precision, dynamic response, impact resistance, torque output, and thermal stability. This article explores six key engineering challenges in quadruped robot development and explains how the HONPINE JRM planetary joint module addresses them through low backlash, fast three-loop response, high torsional stiffness, strong overload capability, smooth speed output, and wide temperature adaptability. It also examines continuous operating conditions and overload limits to help robot developers evaluate joint performance and select suitable planetary joint solutions for high-dynamic industrial inspection robots.