#Product Trends
Automated Gripper Finger Changes for Flexible Robot Handling
One gripper for a variety of workpieces.
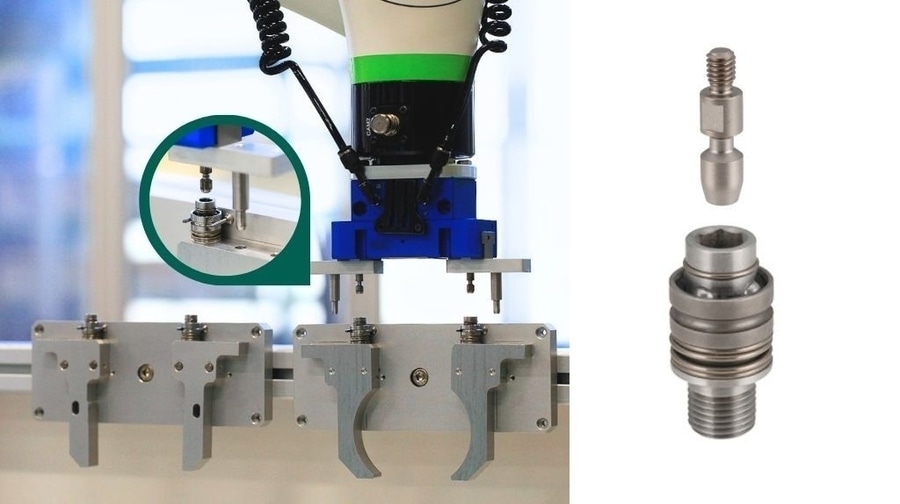
When a robot needs to handle different workpieces, common approaches include replacing the entire gripper with a tool changer or using multiple grippers in one setup. MotionAct Finger Changers offer another option: keeping the same gripper and changing only the fingers.
Finger changes can be performed automatically through simple robot arm movements. The fingers can be locked and unlocked as part of the robot’s normal motion, allowing the change process to be incorporated into the product changeover sequence and eliminating manual finger replacement.
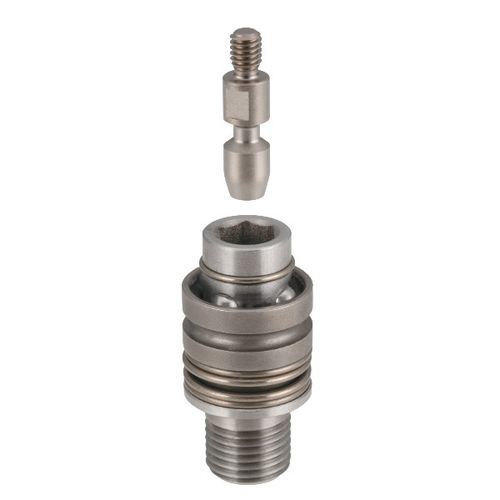
The system can be used with a wide range of grippers. By designing the mounting plate to suit the gripper, MotionAct Finger Changers can be installed on any gripper that can accommodate the clamping pin, without being limited to a specific manufacturer or dedicated gripper design.
Secure locking is achieved entirely through a mechanical ball-and-taper mechanism. When the clamping pin is inserted into the Finger Changer, internal balls engage and firmly retain the pin. The finger remains securely locked until it is released using the retaining pin and robot arm movement. No air piping or electrical wiring is required for the locking mechanism.
Changing only the fingers also helps keep the system compact and lightweight. Compared with replacing the entire gripper, this approach reduces the size and weight of the changeover system and minimizes the impact on robot payload capacity, making it particularly suitable for small robots.
MotionAct Finger Changers can be used in applications such as machine tending and laboratory automation, where a single robot may need to handle different workpieces, parts, or tools. By combining automated finger changes, broad gripper compatibility, secure mechanical locking, and a compact design, the system provides a flexible way to expand the range of tasks that can be performed with a single gripper.