

#Product Trends
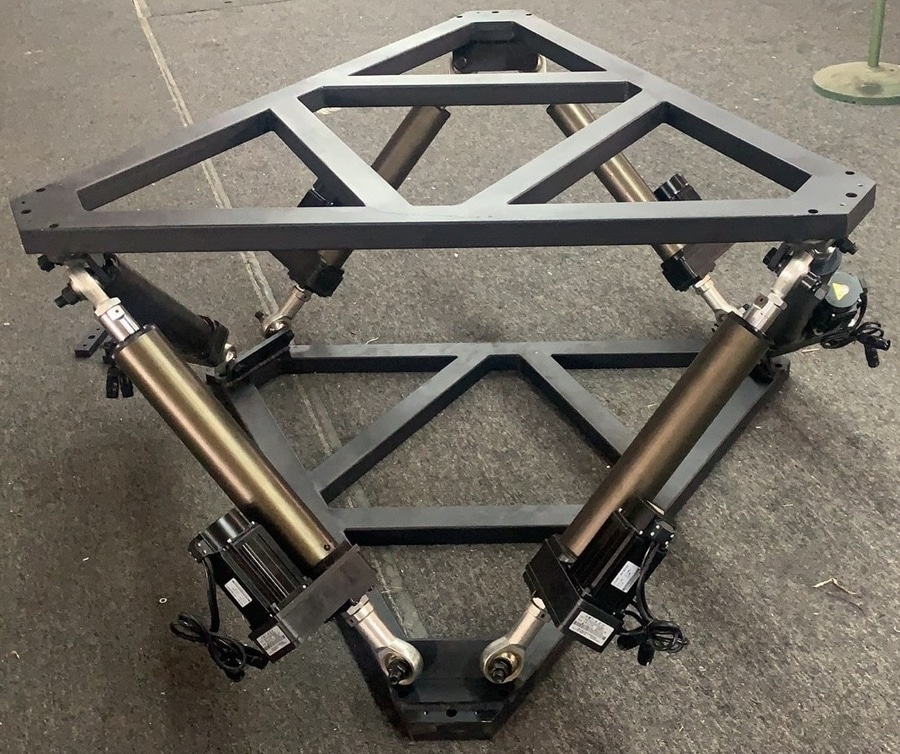
1500KG Payload 6DOF Motion Platform 2m*2m Frame for Truck Simulator
Real-time data communication (UDP)
Our Customer developed a game using Unity 3D. So he required a 1.5Ton Payload 6DOF Motion Platform for Truck Simulator.
We designed a 2m*2m Platform Frame and made the Electrical Carbinet with PLC Controller Panel for our customer.
We utilize CODESYS configuration software from Germany and employ the EtherCAT protocol for network communication. It offers rapid transmission response and is suitable for applications such as vehicle driving simulation and flight simulation.
I. Mechanics – Structure
-1.5Ton Payload 6DOF Motion Platform (2m*2m Frame)
-Spherical joints (Universal Joints/Hooker Joints)
-Hexapod geometry design (6-point coordinates)
-Reinforced base frame (for sufficient rigidity)
-Actuator mounting brackets
-High-strength bolts and connecting pins
II. Motion Control
-Dedicated motion controller
-6-axis servo synchronization (multi-axis sync)
-Trajectory planning/interpolation algorithms
-Software travel limits (software limits)
III. Software & Communication
-Real-time data communication (UDP)
-EtherCAT communication drivers for servos
IV. Sensors & Feedback
-Feedback encoders (if not already sufficiently precise)
-Limit switches
V. Electrical System
-Main electrical cabinet
Circuit breakers, AC contactors, Filters,Intermediate Relays, Switching power supplies, Pushbuttons, Indicator Lights, Other Accessories
-Power and signal cables
VI. System Safety
-Emergency Stop button (E-stop)
-Safety relay
-Mechanical travel limits
-Overload and overcurrent protection
VII. Simulation Cabin
Truck Cabin frame (Kamaz) – Already acquired
VIII. Calibration & Operation
-Actuator stroke calibration (6 units)
-Servo PID tuning
-Vibration filtering & motion stabilization
Pitch, Roll, and Yaw (three rotation angles);// °
Linear accelerations along the X, Y, and Z;// g
Completion time // ms
float Flag = 999; //Defult
/*Rotation angle */
float Pitch_Angle = 0.10; // ~5.7°
float Roll_Angle = 0.12; // ~6.9°
float Yaw_Angle = 0.05; // ~2.8°
/* Acceleration (unit: g) */
float Xacc = 0.25; //
float Yacc = 0.22; //
float Zacc = 0.35; //
/* Sampling cycle */
float Sampling_Periods = 10; // ms (100 Hz)
These data from the Truck game Software need to be sent to the controller.
From Website:https://unite-ch.net/1-5ton-payload-6dof-motion-platform-for-truck-simulator/
Email: [email protected]
Phone/WhatsApp:+86 134 2182 9809
Shenzhen UNI Technology Co., Ltd


