Posted on 9/14/2026
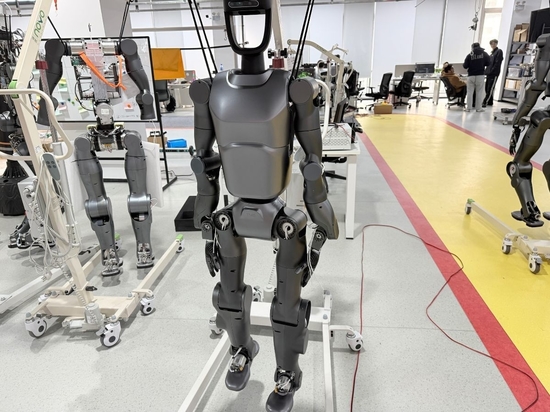
Humanoid joint motor design should focus on joint-specific system-level optimization, balancing torque density, precision, speed, backdrivability, thermal performance, control response, weight, and integration rather than simply maximizing motor
The article explains that a high-performance humanoid joint motor is more than a powerful electric motor—it is a complete motion system combining the motor, reducer, encoder, driver, brake, sensors, bearings, and housing. Different joints such as hips, knees, shoulders, wrists, and fingers have different requirements, so the actuator should be designed around the specifi...