Posted on 9/21/2026
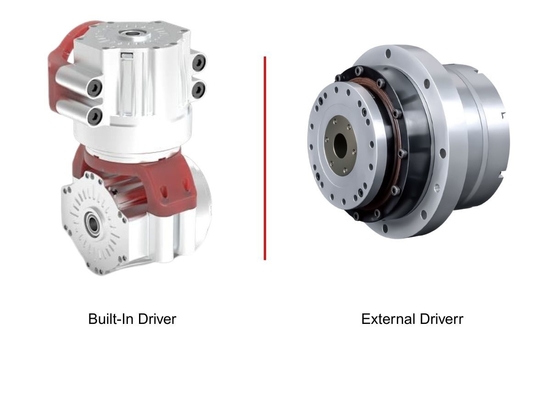
A built-in or external driver should be selected based on the actuator’s space, wiring, thermal, control, and maintenance requirements.
Harmonic Rotary Actuators can use either built-in or external drivers, with each configuration suited to different machine architectures. Built-in drivers are useful for compact robotic joints, humanoid robots, collaborative robots, and applications where space and wiring are major constraints, while external drivers offer greater flexibility for CNC systems, semiconduct...